|
Zhengtao Han | 韩峥涛 I'm an undergraduate student in Computer Science at ShanghaiTech University. In Fall 2025 I was a visiting student at UC Berkeley, working with Koushil Sreenath at the Hybrid Robotics Lab. I have also worked with Chuang Gan and Yilun Du at the UMass Embodied AGI Lab, Tianmin Shu at the JHU Social Cognitive AI Lab, and Yi Wu at Shanghai Qi Zhi Institute. I currently work with Chong Zhang on deformable object manipulation. Email / X |
|
ResearchI am interested in robot learning, with a focus on robot manipulation. I aim to bridge the gap between the broad knowledge of foundation models and reliable action in the physical world. I am particularly interested in enabling robots to adapt in unfamiliar scenes and improve their capabilities through experience. |
All Publications
First / co-first author papers are highlighted. * denotes equal contribution.
|
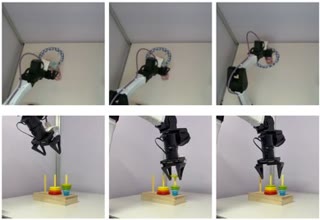
HiRE: Hindsight Reward Editing for Policy Finetuning
Haoyi Niu*, Zhengtao Han*, Yufeng Ji, Zhongyu Li, Koushil Sreenath CoRL, 2026 project page / arXiv A training-free framework that turns frozen foundation visual encoders into control-aware rewards by contrasting successful and failed rollouts in hindsight. |
|
SyncWorld: Visual Calibration Enables World Models as Zero-Shot Simulators
Yuncong Yang*, Zhengtao Han*, Furkan Özyurt*, Zeyuan Yang, Han Yang, Junyi Cao, Haoyu Zhen, Yilun Du, Chuang Gan NeurIPS, 2026 (Oral, Top 0.3%) project page / arXiv SyncWorld infers the setup-specific action-visual mapping in context from a short visual calibration episode, enabling robot world modeling across unseen camera views, environments, and embodiments without downstream training. |
|
|
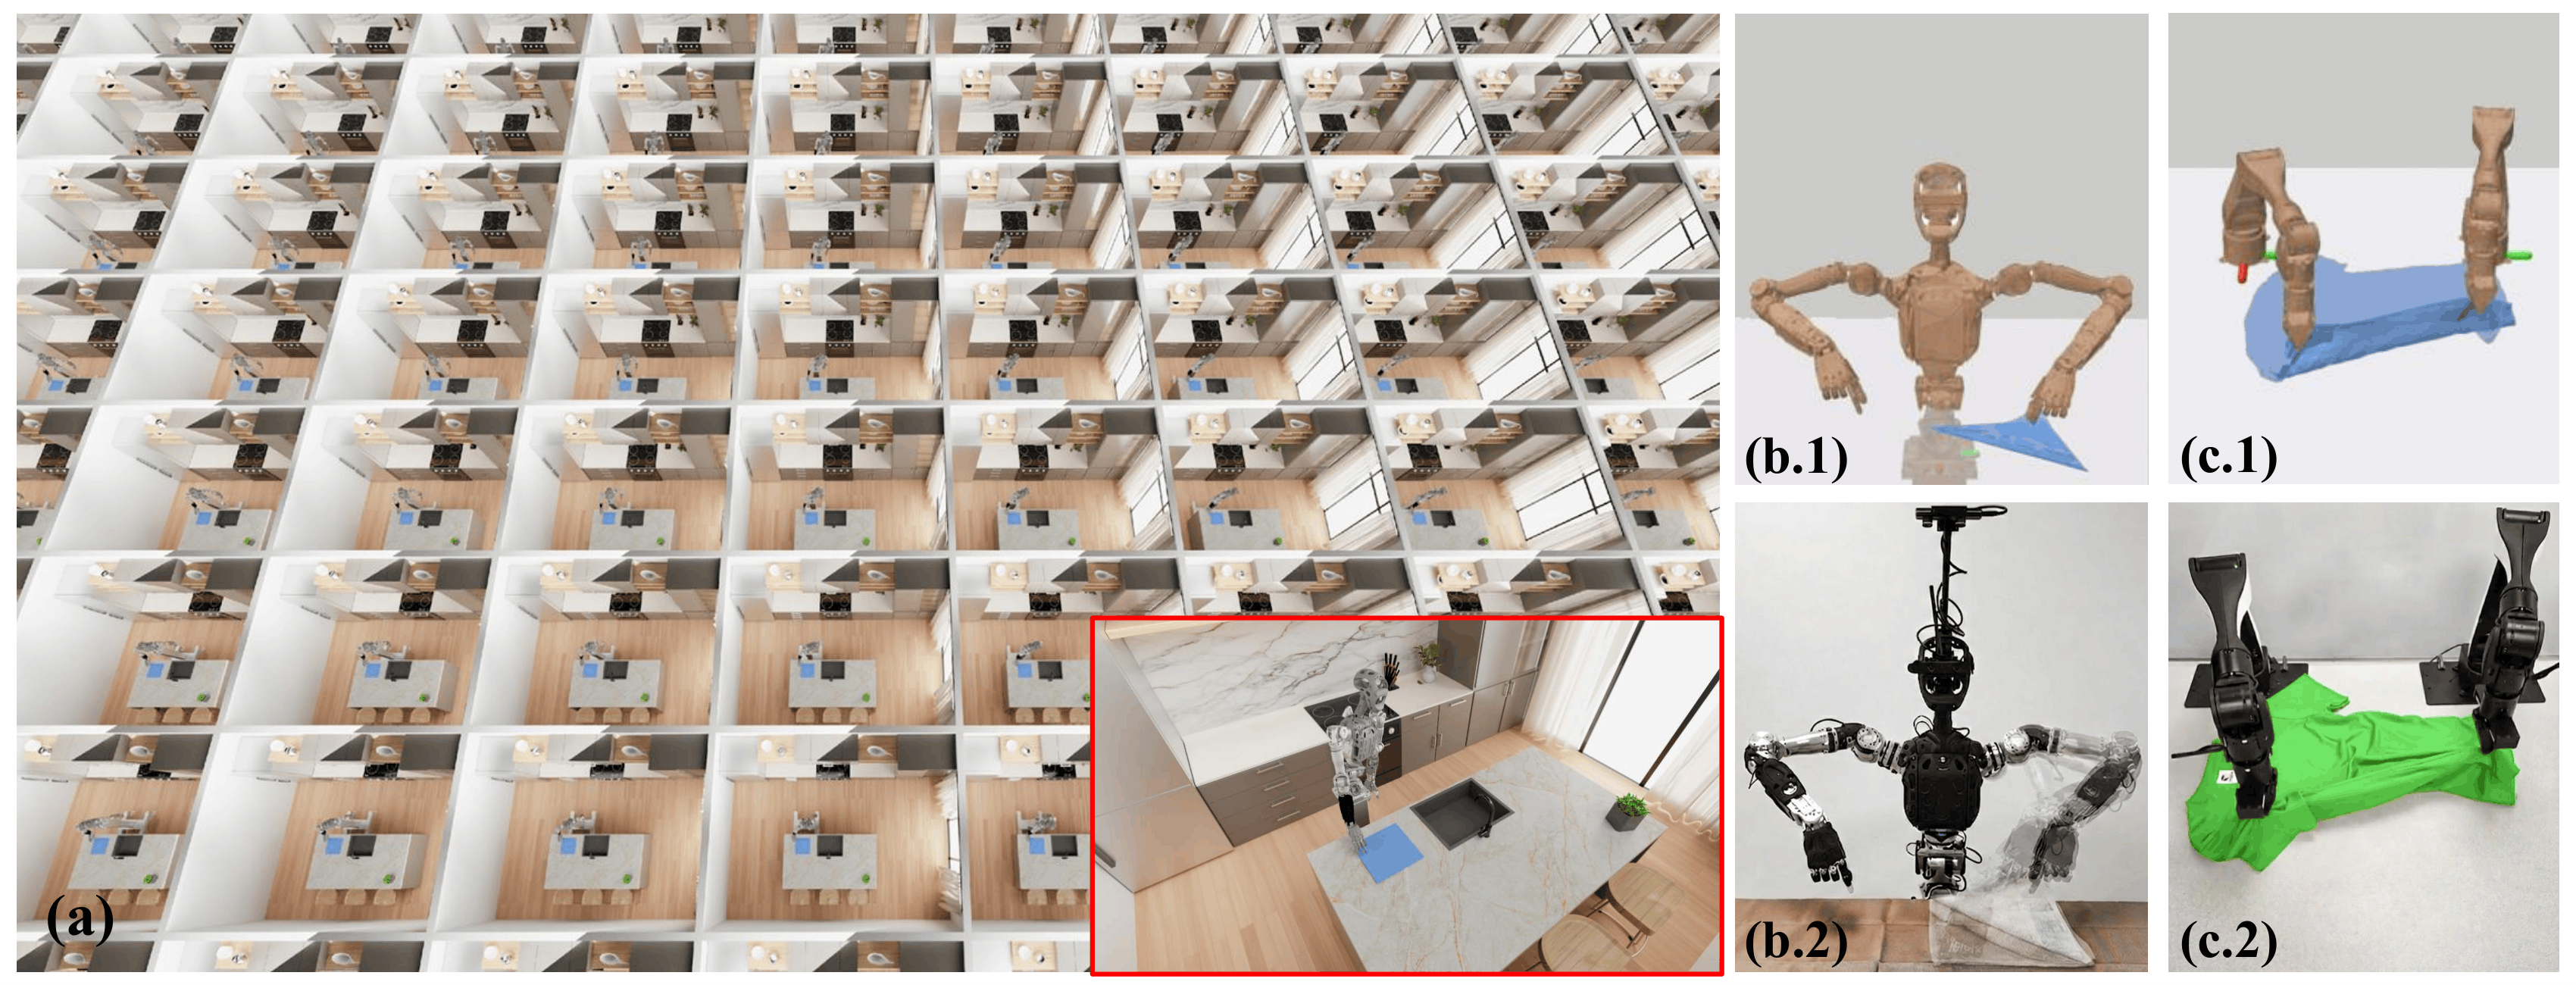
FLASH: Fast Learning via GPU-Accelerated Simulation for High-Fidelity Deformable Manipulation in Minutes
Siyuan Luo*, Bingyang Zhou*, Chong Zhang*, Xin Liu, Zhenhao Huang, Gang Yang, Zhengtao Han, Xiaotian Hu, Eric Yang, Rymon Yu, Ziqiu Zeng, Fan Shi ISRR, 2026 arXiv A GPU-accelerated simulator for high-fidelity deformable object manipulation, built for fast policy learning. |
|
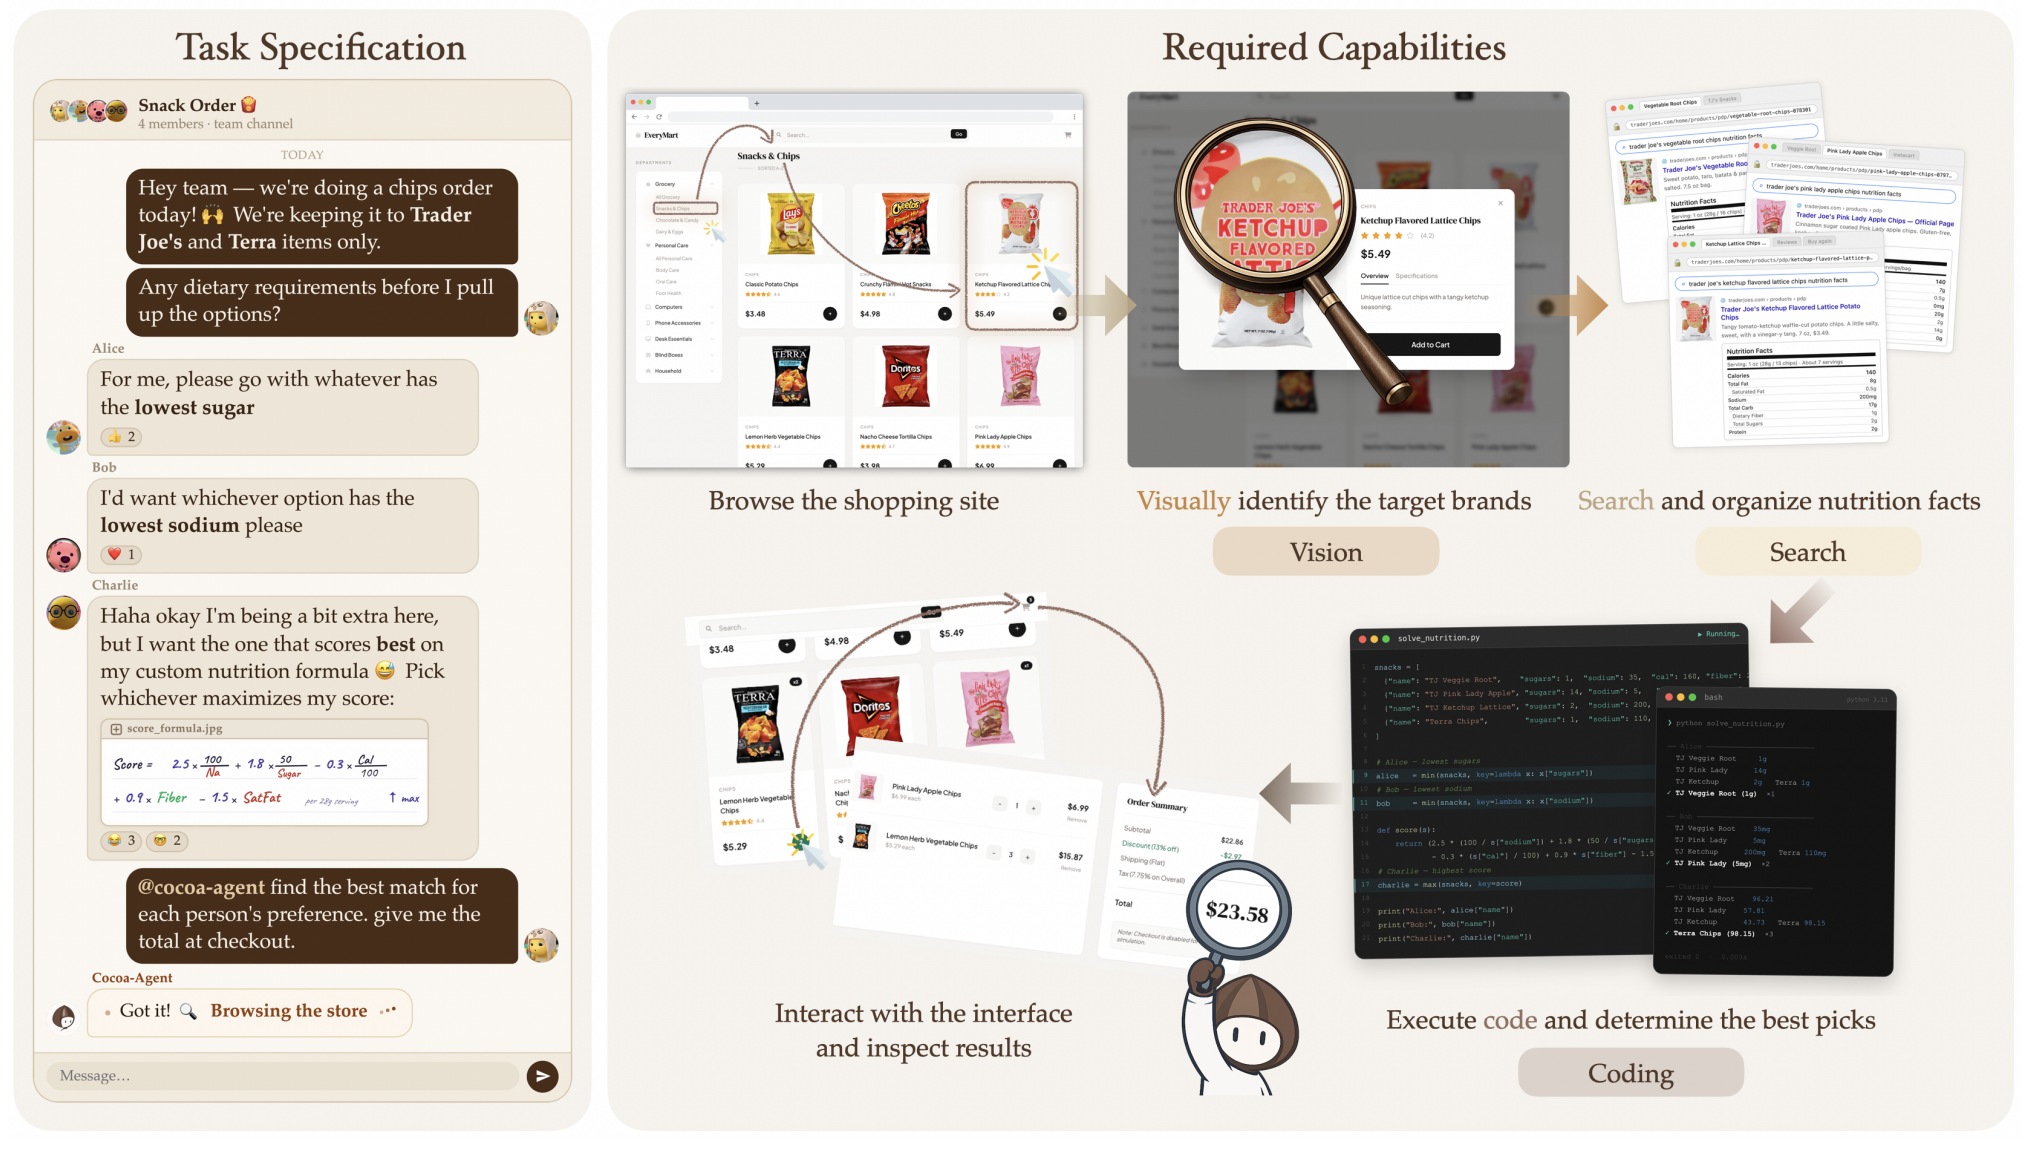
CocoaBench: Evaluating Unified Digital Agents in the Wild
Shibo Hao*, Zhining Zhang*, Zhiqi Liang*, Tianyang Liu*, ..., Zhengtao Han, ..., Zhiting Hu COLM, 2026 project page / arXiv A benchmark for digital agents that must perceive and act across websites, terminals, and files in the wild. |
|
PartInstruct: Part-level Instruction Following for Fine-grained Robot Manipulation
Yifan Yin*, Zhengtao Han*, Shivam Aarya, Shuhang Xu, Jianxin Wang, Jiawei Peng, Angtian Wang, Alan Yuille, Tianmin Shu RSS, 2025 project page / paper A large-scale benchmark for part-level instruction following in fine-grained manipulation, with 513 objects, 1,302 tasks, and 10,000+ expert demonstrations annotated with 3D parts. |
|
Website template from Jon Barron. |